Javier Gil Avilés
Perception & AI Robotics Engineer — working on computer vision
I build perception and learning systems that let robots understand and act in the real world.
01About
Robots that see, understand and act.
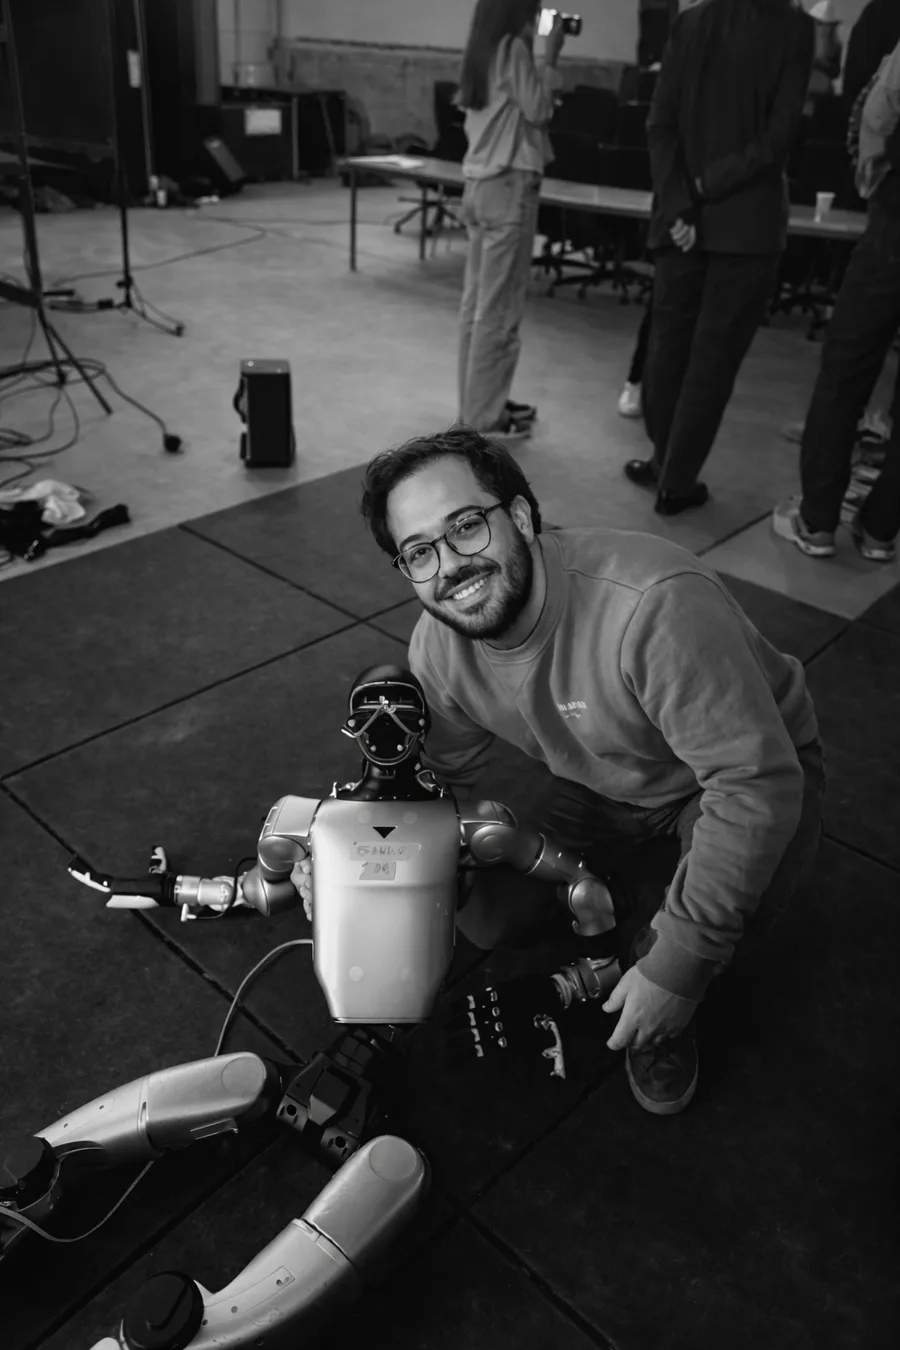
I'm a Spanish robotics engineer, born in Buenos Aires and trained in Seville. After a BSc and an MSc in electronics, robotics and automation at the University of Seville (top 10% and top 5%), I moved to the Netherlands for a second MSc in Robotics at TU Delft, focused on computer vision and AI.
Before Delft I worked on real systems: multi-obstacle tracking for a Navantia unmanned surface vessel at the GRVC lab, and Fast DDS middleware plus the SustainML backend at eProsima. Today I do computer vision research at Hilti AG and collaborate with ETH Zurich's Computer Vision and Geometry group (CVG) on a paper in preparation. I also do part-time AI engineering at VIKTOR and hackathon builds with real arms, humanoids and robot dogs.
Outside the lab I lead the robotics vertical at EuroTech Federation, connect students with industry as External Affairs at ASIMOV, and lead perception for the Delft Neptunians underwater robotics team.
Now
- Computer Vision Research at Hilti AG
- Co-authoring a paper with ETH Zurich's Computer Vision and Geometry group (CVG)
- Robotics Vertical Lead at EuroTech Federation
- MSc Robotics at TU Delft, computer vision & AI track
- AI Engineer (part-time) at VIKTOR, building MCP and RAG tooling
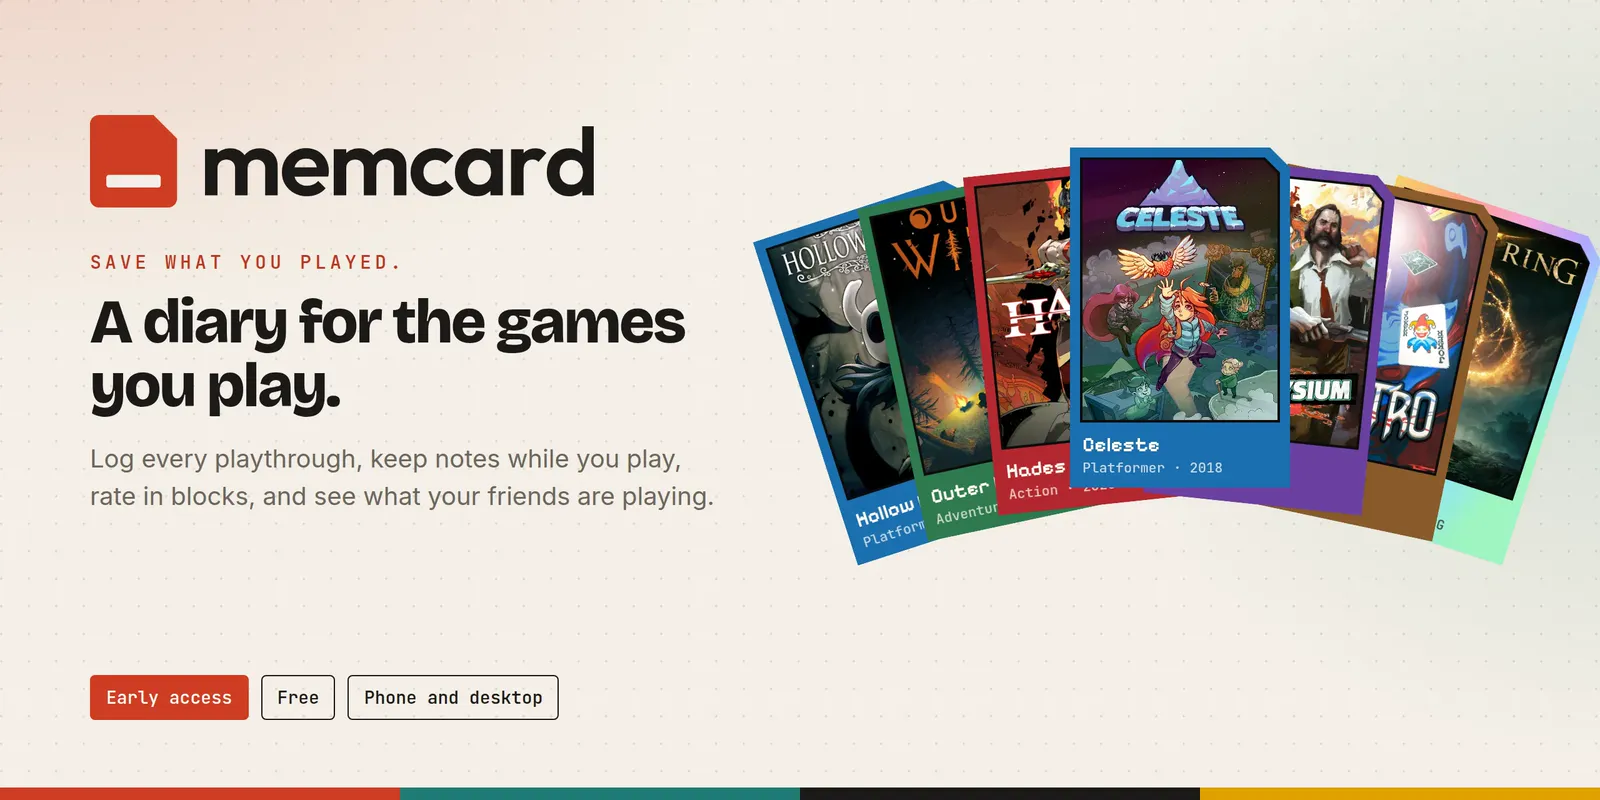
- Building memcard, a social diary for video games
- 2+
- years in industry & research
- 20+
- robotics & AI projects
- 2
- hackathon wins in 2026: RoboHack EPFL & ERH Zurich
- Top 5%
- MSc, University of Seville
02Selected work
Things I've built.
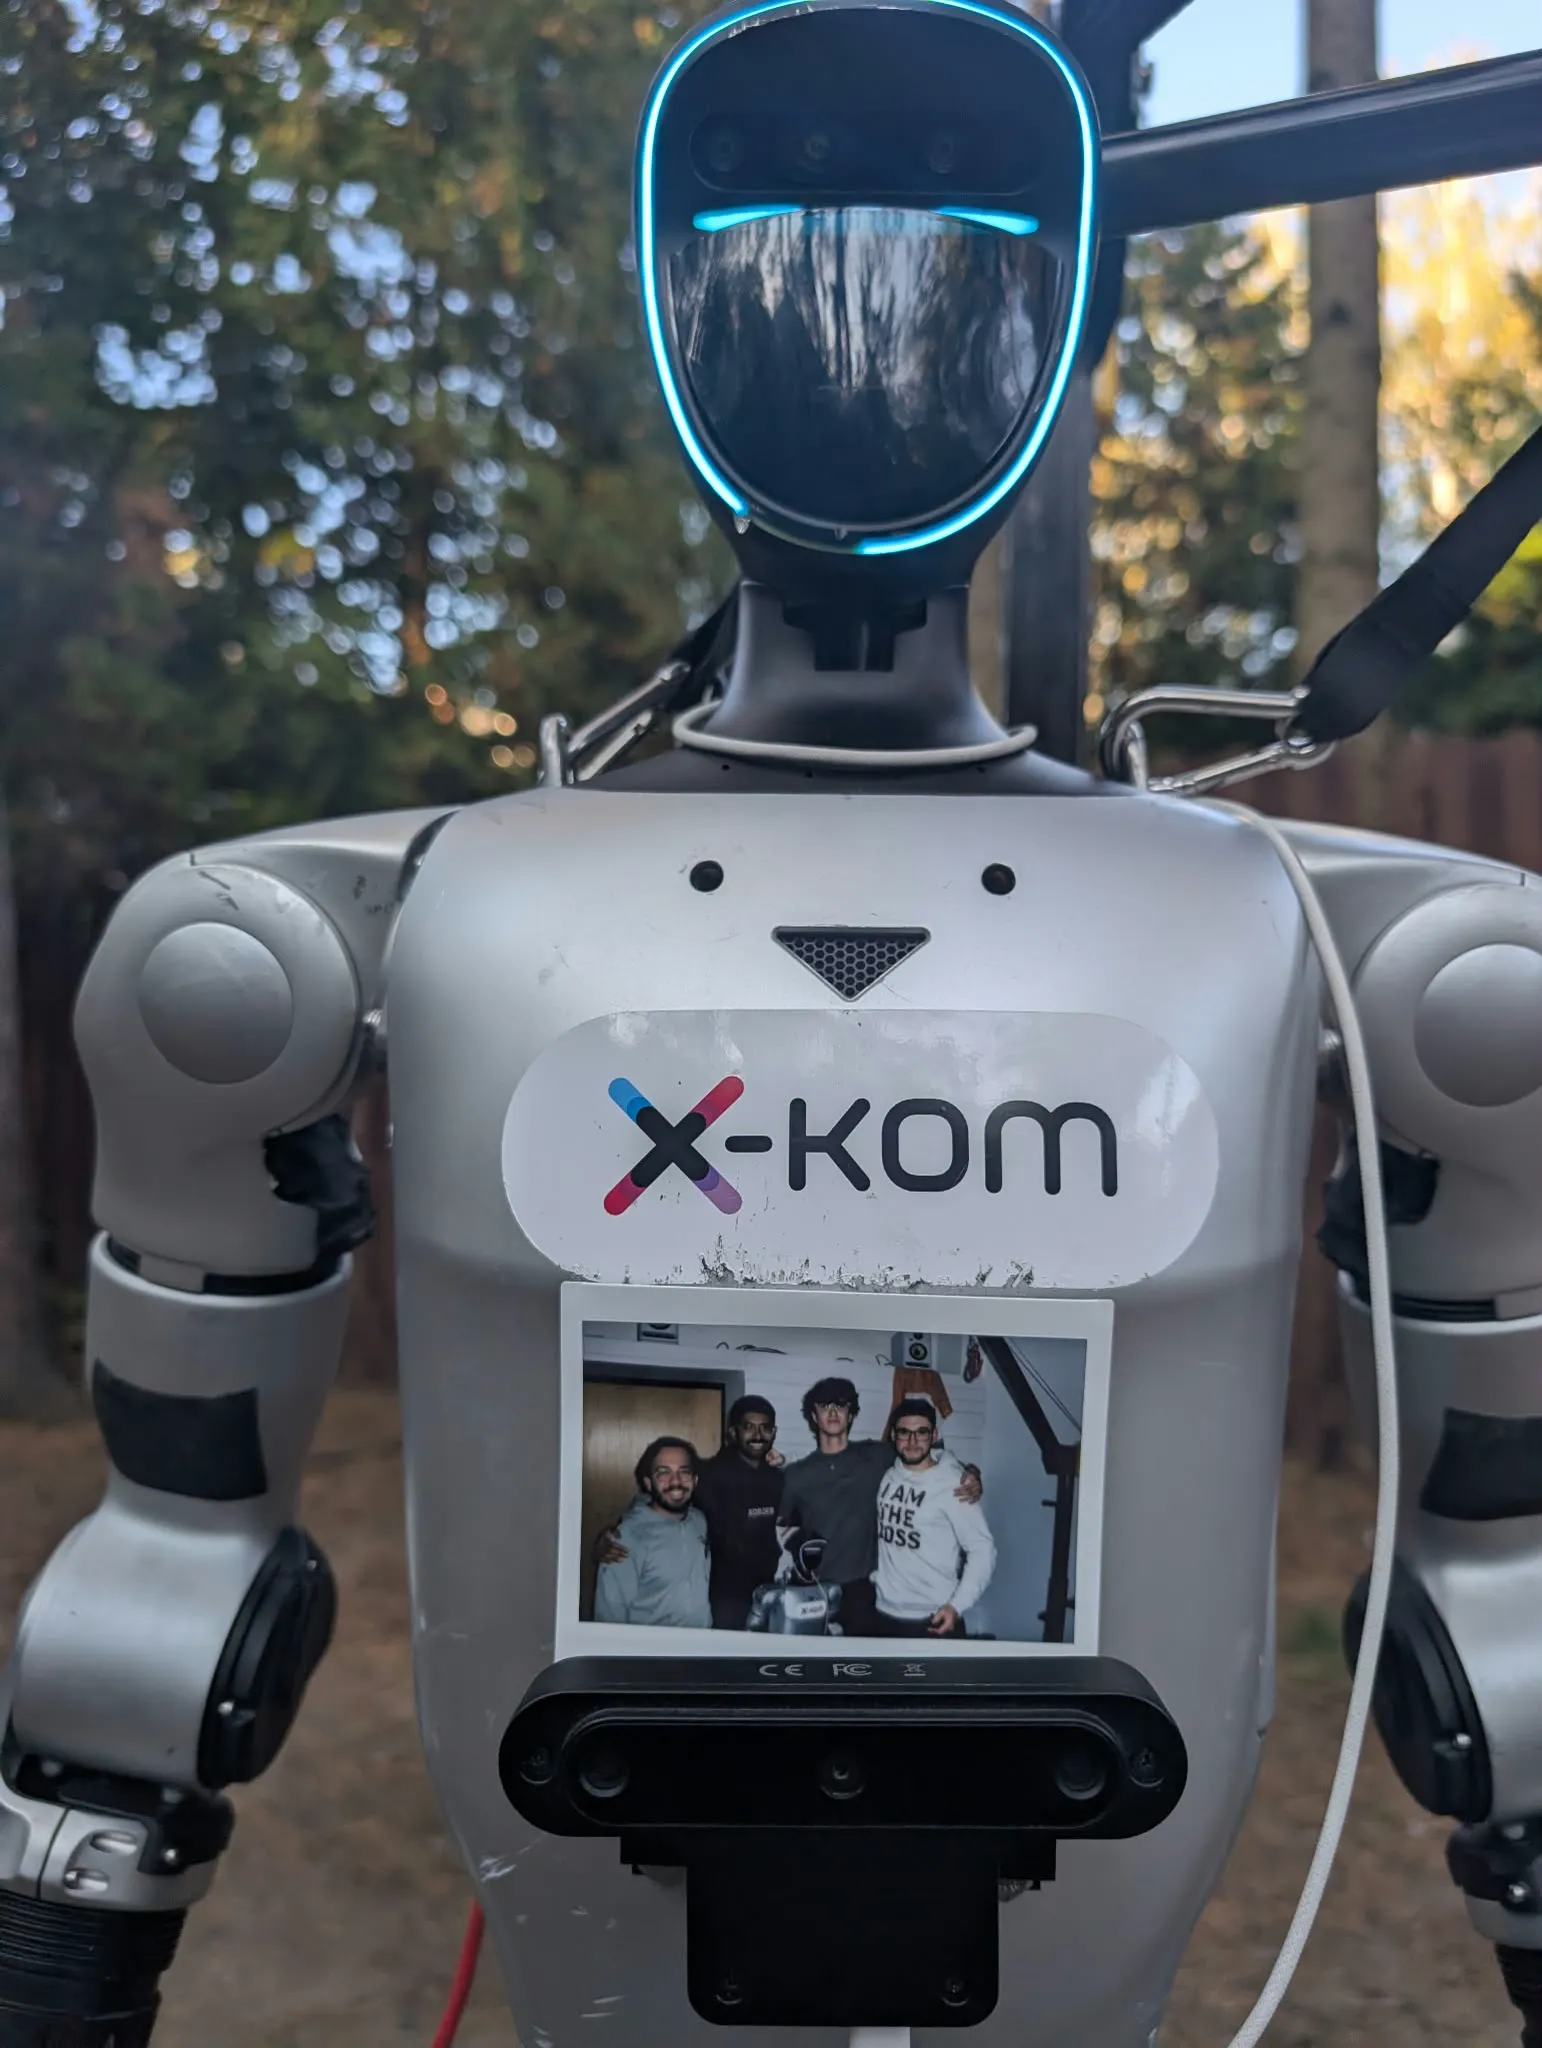
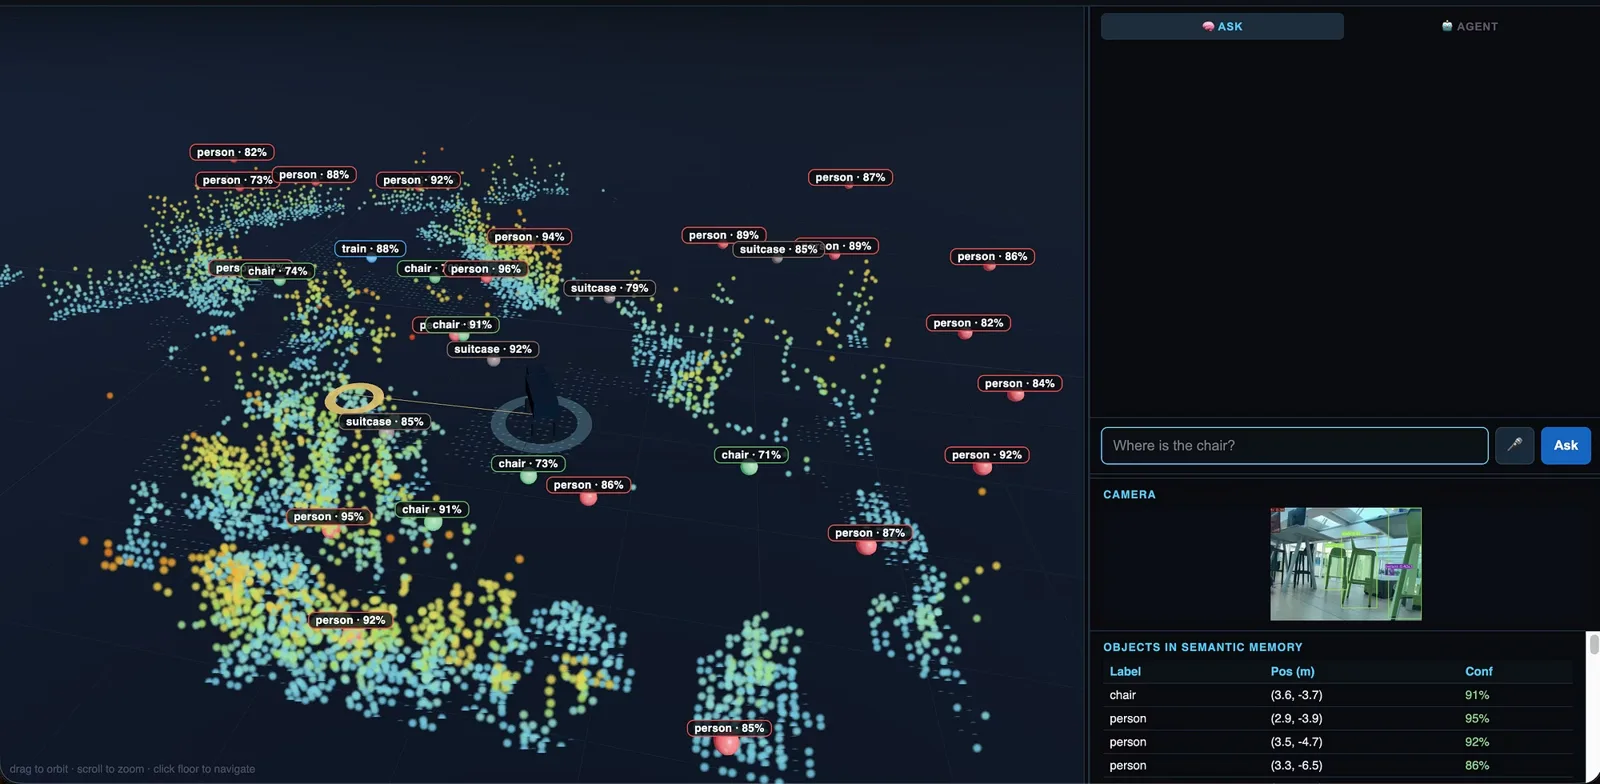
Physical-AI hackathon builds, perception pipelines, research and products. Open any card for the full story, media and links.
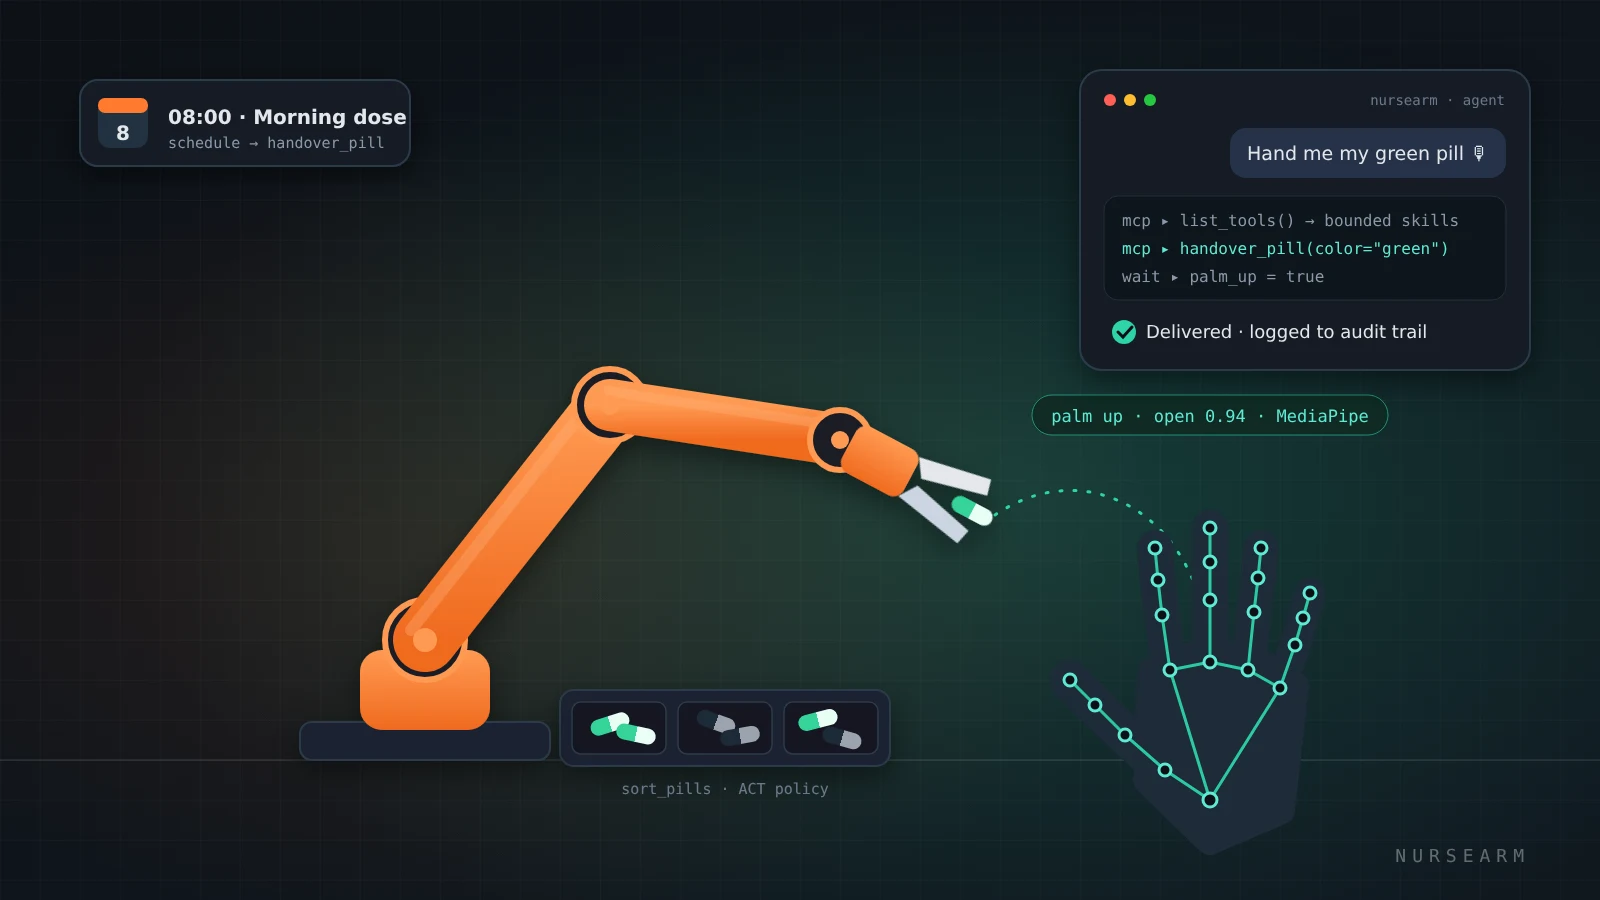
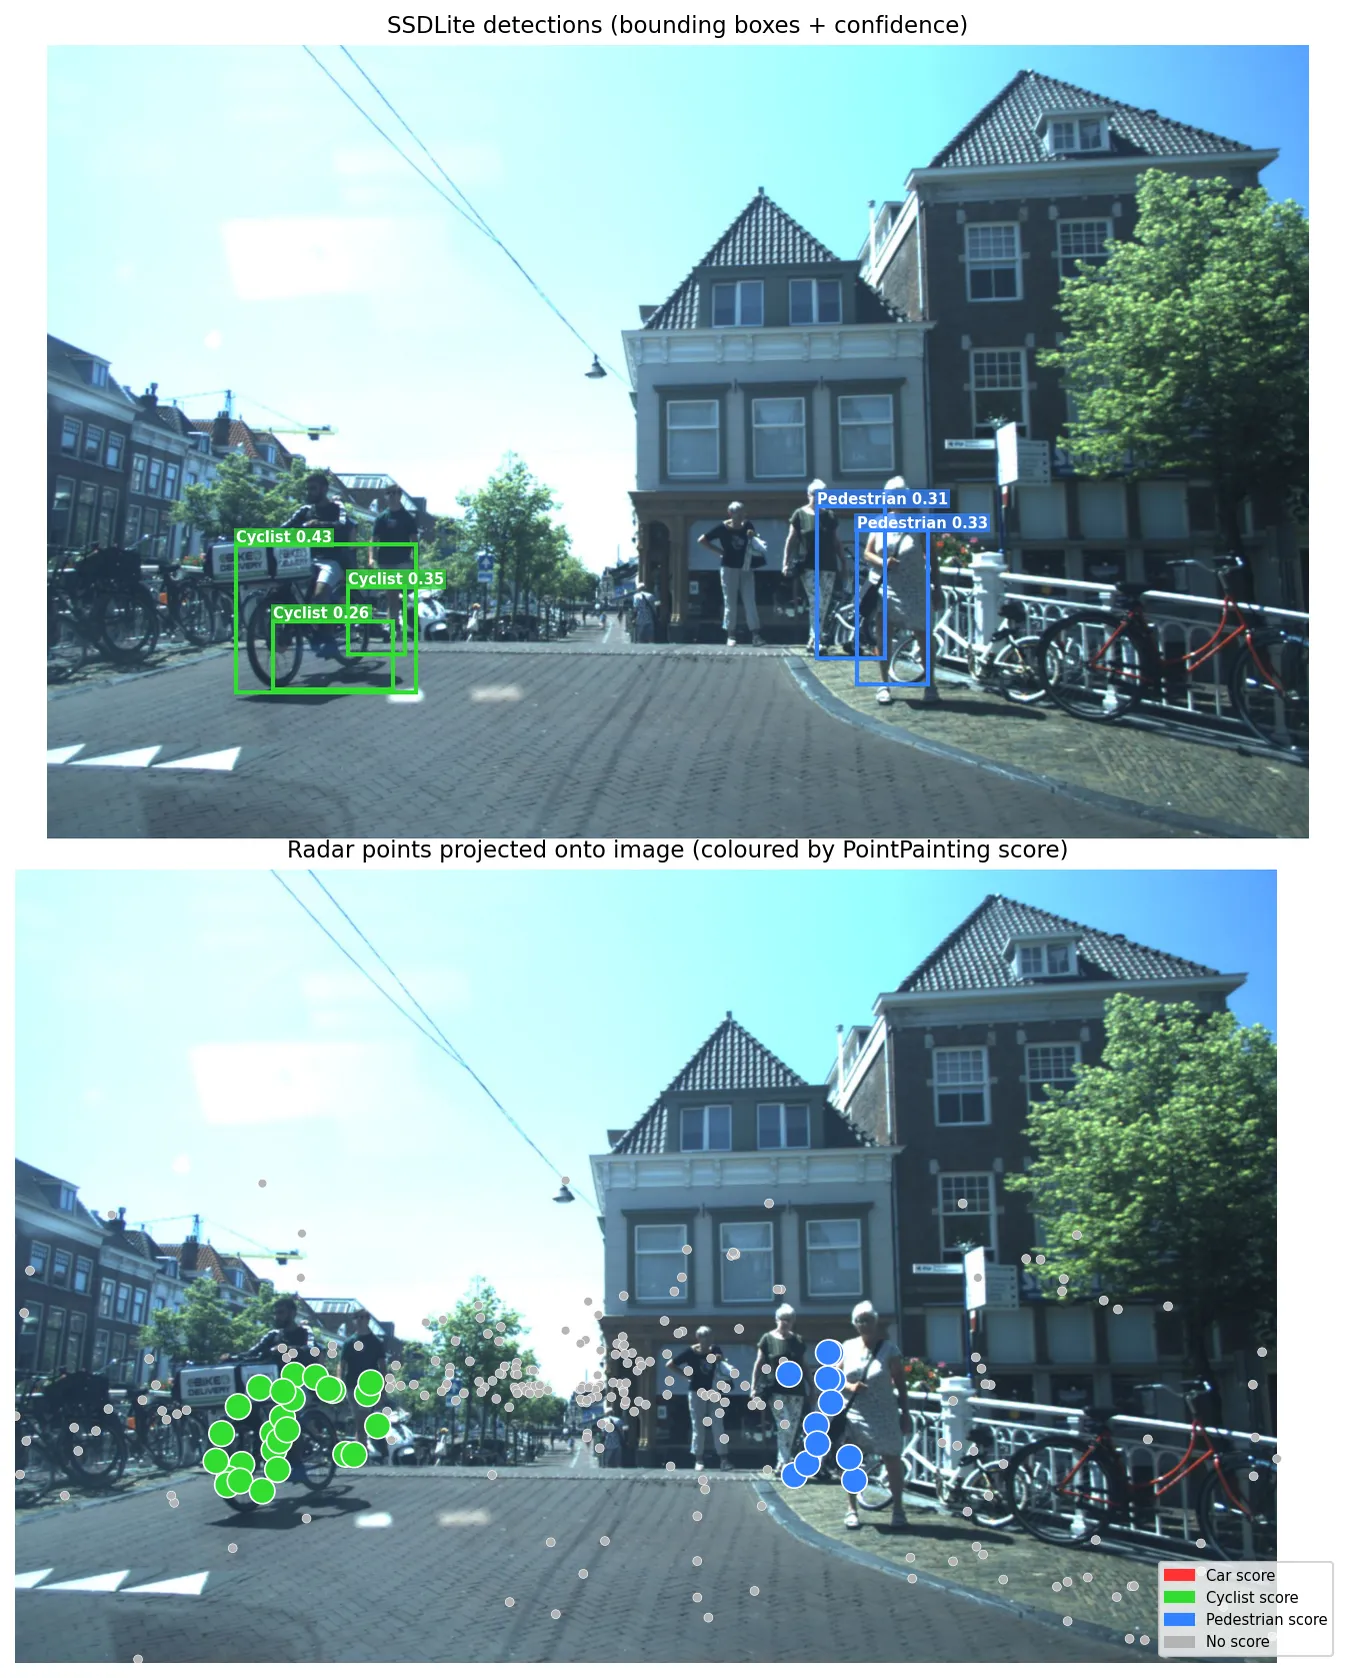
More projects
- DINO-WM ReproductionReproducing zero-shot planning with world models on frozen DINO features, and testing DINOv3.2026
- Greenhouse Surveillance RobotAutonomous exploration, mapping and AprilTag localization for a Mirte robot in a greenhouse.2026
- AI for Industry ChallengePerception for robotic cable insertion in Intrinsic's industrial manipulation challenge.2026
- Traffic-Sign Attack GeneratorPhysical adversarial shadows and occlusions for stress-testing traffic-sign recognition.2026
- Mirte Symbolic Task PlanningPDDL planning with PlanSys2 to sequence move, pick, place and dishwasher actions on a Mirte robot.2026
- CentauriA Chrome extension that runs web tasks from natural language in a floating command shell.2026
03Experience
Industry & research.
From maritime tracking and ROS 2 middleware to computer vision research at Hilti and ETH Zurich.
Hilti AG
2026 — present · Schaan, Liechtenstein
Hilti AG
2026 — present · Schaan, Liechtenstein
Computer Vision Research
hilti.group- Computer vision research for construction: 3D perception and mapping from site captures.
- Computer vision
- 3D perception
- SLAM
ETH Zurich · Computer Vision and Geometry Group (CVG)
Aug 2026 — present · Zurich, Switzerland (remote)
ETH Zurich · Computer Vision and Geometry Group (CVG)
Aug 2026 — present · Zurich, Switzerland (remote)
Research collaborator
cvg.ethz.ch- Co-authoring a paper in preparation on geometric minimal solvers for camera pose estimation.
- C++ solver work, RANSAC and numerical-stability studies, and real-data localization experiments on ETH3D.
- Open-source fix merged into CVG's LIMAP mapping toolbox (multiscale line-descriptor serialization, PR #169).
- Multi-view geometry
- Minimal solvers
- C++
- PoseLib
- LIMAP
VIKTOR
Mar 2026 — present · Rotterdam, Netherlands
VIKTOR
Mar 2026 — present · Rotterdam, Netherlands
AI Engineer (part-time)
viktor.ai- R&D on internal AI tooling, including Model Context Protocol (MCP) servers and retrieval-augmented generation (RAG).
- MCP
- RAG
- LLM tooling
eProsima
Oct 2024 — Aug 2025 · Madrid, Spain
eProsima
Oct 2024 — Aug 2025 · Madrid, Spain
Robotics Software Engineer
eprosima.com- Contributed to Fast DDS, the OMG-standard middleware behind low-latency ROS 2 communication.
- Lead backend developer for the EU SustainML project, which helps developers build ML models with lower CO₂ emissions.
- Built a C++ backend exposed to Python through SWIG, with DDS communication, a Qt/QML frontend and REST APIs.
- Integrated transformer models and RAG pipelines with European research and industry partners.
- C++
- Fast DDS
- SWIG
- Qt/QML
- RAG
GRVC Robotics Lab · University of Seville
Sep 2023 — Sep 2024 · Seville, Spain
GRVC Robotics Lab · University of Seville
Sep 2023 — Sep 2024 · Seville, Spain
Robotics Research Assistant
grvc.us.es- Built a real-time multi-sensor, multi-obstacle tracking system for Navantia's unmanned surface vehicle.
- Worked with ROS 2 and computer vision on both simulated and real robots.
- Turned research concepts into working software for Horizon Europe aerial-robotics projects.
- ROS 2
- C++
- Kalman filters
- Sensor fusion
FlyROS
Sep 2023 — Sep 2024 · Seville, Spain
FlyROS
Sep 2023 — Sep 2024 · Seville, Spain
Project Engineer
aerostream.fer.hr- Represented FlyROS and the University of Seville in the Horizon Europe AeroSTREAM project, supporting aerial-robotics development in Croatia and Bosnia & Herzegovina.
- Horizon Europe
- Aerial robotics
Alter Technology TÜV Nord
Feb 2023 — May 2023 · Seville, Spain
Alter Technology TÜV Nord
Feb 2023 — May 2023 · Seville, Spain
Digitalization & Radiation Engineering Intern
altertechnology-group.com- Studied space-radiation effects on EEE components in the Space Parts Laboratory and automated COTS test-data digitalization with a Python tool.
- Python
- Space hardware
04Toolbox
Skills & tools.
01Perception
- Computer vision
- 3D detection
- Visual SLAM
- Sensor fusion
- Kalman filters
- Multi-object tracking
- Particle filters
- Gaussian splatting
- OpenCV
- YOLO / YOLOE
- MediaPipe
- DINOv2 / v3
02Robot learning
- PyTorch
- VLA / ACT policies
- LoRA fine-tuning
- World models
- Knowledge distillation
- LeRobot
- Teleoperation datasets
- Hugging Face
- SLURM / HPC
03Robotics & simulation
- ROS 2
- Fast DDS
- Nav2
- RTAB-Map
- MPC
- PRM / RRT*
- PDDL / PlanSys2
- Behavior trees
- MuJoCo
- Gazebo
- PyBullet
- Webots
- Isaac Lab
04Agents & LLMs
- LLM agents
- MCP
- RAG
- Claude / Claude Code
- Amazon Bedrock
- Ollama
- Playwright
- Speech (Whisper, ElevenLabs)
05Software engineering
- C++
- Python
- C
- MATLAB
- SQL
- CMake
- SWIG
- Qt / QML
- Linux
- Docker
- Git
- GitHub Actions
06Web & cloud
- TypeScript
- Next.js
- React
- Tailwind CSS
- FastAPI
- PostgreSQL
- REST APIs
- Vercel
- AWS (EC2, S3)
- Chrome extensions
05Education & leadership
Learning, leading, competing.
Education
2025 — present
MSc Robotics
Delft University of Technology
Computer vision & AI track: Machine Learning for Robotics, Advanced Machine Perception, Computer Vision, 3D Vision. Honours Programme student.
2024 — 2025
MSc Electronic, Robotics & Automation Engineering
University of Seville
Top 5%. Thesis: multi-sensor, multi-obstacle tracking for maritime vehicles (C++, ROS 2, Fast DDS), validated at GRVC.
2019 — 2023
BSc Electronics, Robotics & Mechatronics Engineering
University of Seville
Top 10%. Thesis: classical vs CNN road-lane detection for autonomous guidance. 10/10 in Robot Fundamentals and Perception Systems.
Leadership & community
Robotics Vertical Lead, EuroTech Federation
2026 — presentEuropean student tech federation · co-organizer of the ERH Physical AI Hackathon
Leading the robotics vertical: building a European community of robotics students and builders through hackathons, events and partners.
External Affairs, ASIMOV
2025 — presentTU Delft robotics study association · VI Board
Connecting more than 650 robotics engineers with companies such as MathWorks, NVIDIA and Festo, and with events and hackathons.
Perception Lead, Delft Neptunians
2025 — presentRAMI 2026 marine robotics competition
Designing the ROS 2 perception stack (localization and target detection) for an autonomous underwater robot.
Co-founder & CTO, ServiAgro
2024Innovation Prize, XIX Entrepreneurship Ideas Competition (US × Chamber of Commerce)
Modular retrofit kit that automates and digitalizes legacy agricultural machinery.
Vice President, ESTIEM LG Seville
2024 — 2025European students of industrial engineering
Organized events linking engineering students and companies. Winner of the TIMES 2021 local round and 2nd in the Karlstad semifinal.
Member, The Exponential Fellowship
Spanish AI & software community
Part of a network of young software and AI builders from Spain.
Awards & certifications
- 1st place — RoboHack 2026 at EPFL2026
ArgOS: natural-language control for a Unitree Go2
- Track prize — ERH Physical AI Hackathon, Zurich2026
Liminal: dual-arm manipulation with FLUX 3 Action and Claude
- Innovation Prize — XIX Entrepreneurship Ideas Competition2024
ServiAgro · University of Seville & Chamber of Commerce
- 2022
Lane-detection lead — Autonomous Driving Challenge
SEAT × CUPRA × Volkswagen, University of Seville team
- 2021
TIMES 2021 — 1st local round, 2nd Karlstad semifinal
ESTIEM international case-study competition
- 2025
IBM — AI Fundamentals with Capstone
Certification
- 2024
Business for All
Certification · Harvard Business Publishing × Santander Open Academy
06 — Contact
Let's build something that moves.
Open to internships and roles in perception, computer vision and physical AI, worldwide. I reply fastest by email.